Design engineers pushing machines to lower cycle times often sacrifice positioning accuracy.
The obstacle engineers frequently overlook is torsional windup (elastic twisting under dynamic loads) and settling time lag.
Instead of evaluating gearheads solely on backlash, consider a gearhead’s torsional rigidity, or how the gearhead resists twisting when subjected to high acceleration torques. This ultimately dictates how fast your system stabilizes at the end of a move.
Here is an analysis of why torsional windup creates machine bottlenecks and how a gearhead can be better engineered to solve it.
The Challenge: Micro-Vibrations and Extended Settling Times
When a high-inertia load is rapidly accelerated and abruptly decelerated, dynamic torque spikes exert intense force across the gear train. In standard gearhead designs, three internal components act like torsion springs:
-
Cantilevered Planet Pins: Unsupported or single-supported planet pins deflect under peak torque, causing slight gear teeth misalignment.
-
Carrier Housing Flex: Split or light-duty planet carriers twist relative to the output interface, introducing rotational lag.
-
Shaft Torsion: Long output shafts add compliance, allowing the load to “ring” (oscillate) at the end of the motion profile.
The result is an extended settling time. The servo controller registers that the encoder position is reached, but end-of-arm tooling continues to micro-vibrate due to stored mechanical spring energy.
Automation engineers are forced to add artificial pause times to their PLC logic to let the system stabilize, directly undercutting the machine’s overall throughput.
How to Redesign a Gearhead to Achieve Greater Torsional Rigidity
A better engineered gearhead must provide structural stiffness that translates into instantaneous position holding:
1. Look for Integrated Straddle-Bearing Carrier Designs
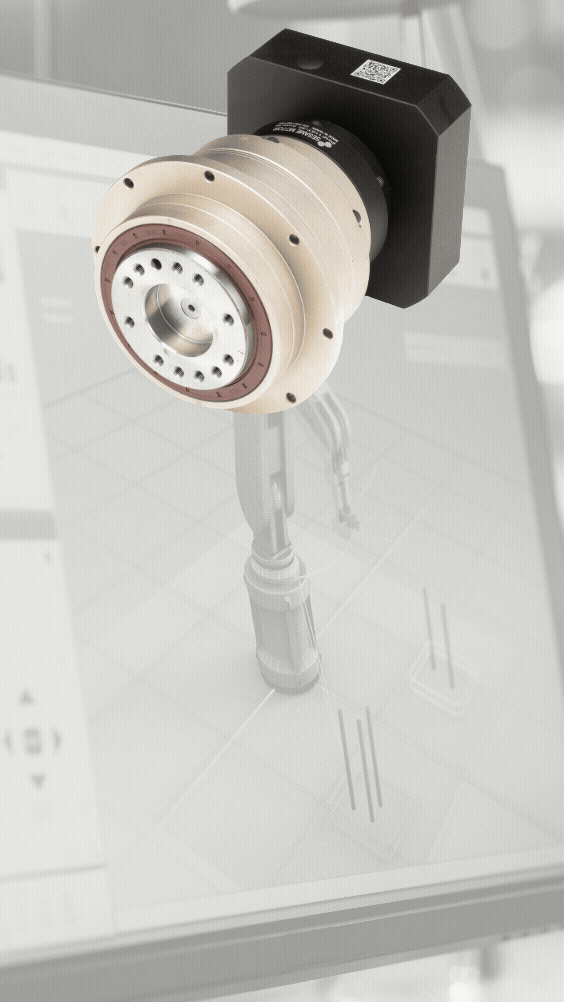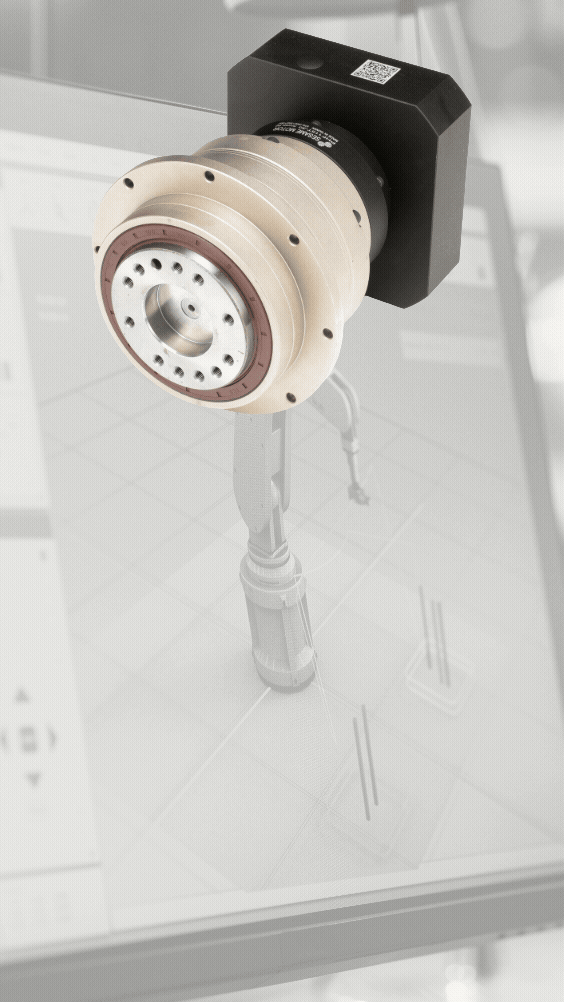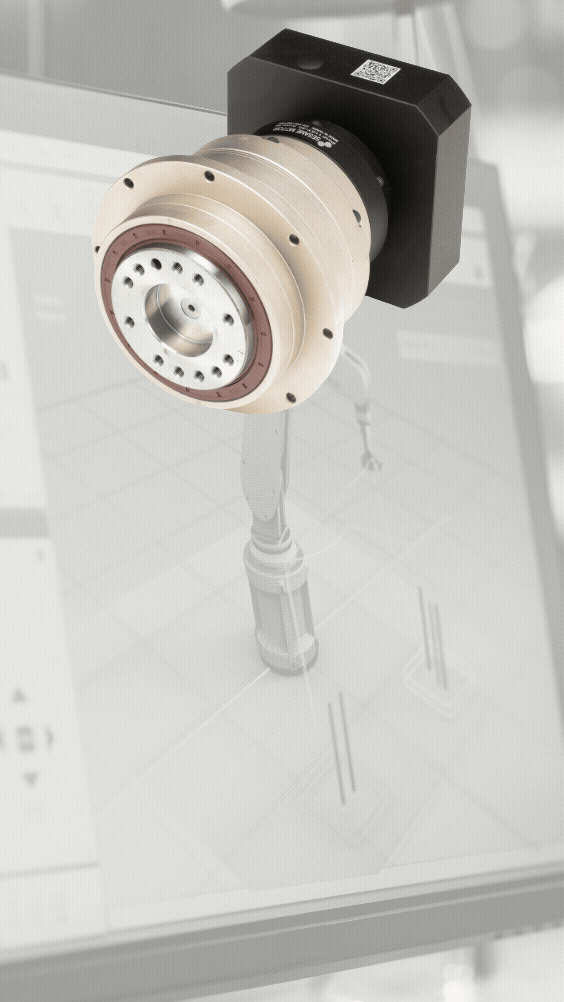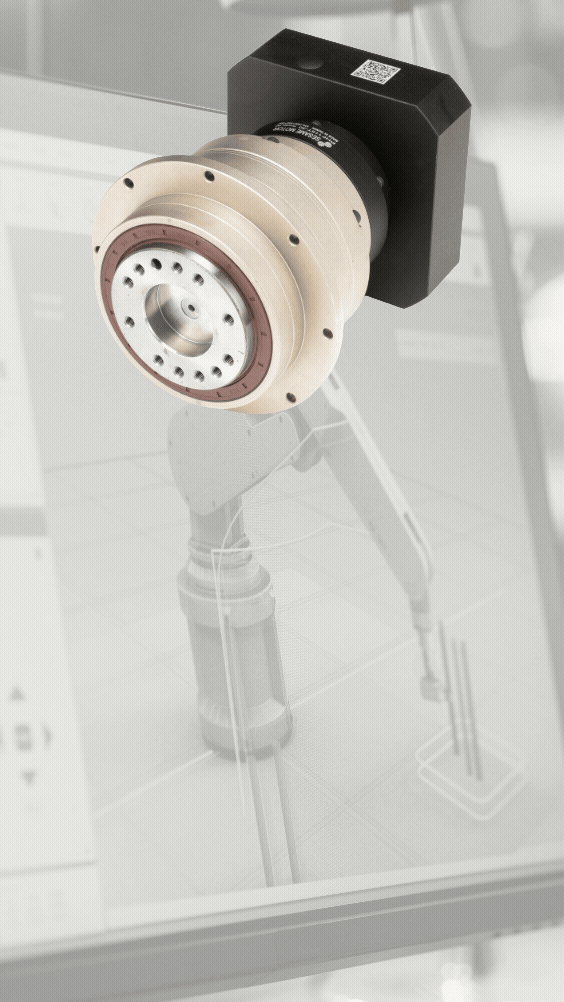
Instead of relying on a multi-piece or bolt-together assembly, the gearhead is built with a one-piece planet carrier where the output flange interface and internal cage are manufactured as a single rigid steel structure. Supported on both ends with full needle bearings on the planet shafts, gear straddle-deflection is virtually eliminated under maximum load conditions.
2. Minimize Output Shaft Length via Direct Flange Interfaces
By utilizing an ISO 9409-1 robotic output flange rather than a traditional keyed or smooth output shaft, torque transmission occurs over a large pitch circle diameter. The elimination of a long, narrow output shaft reduces torsional deflection to an absolute minimum.
3. Optimize Tooth Contact Overlap for Dynamic Deceleration
A helical gear mesh provides high tooth-contact overlap compared to standard spur gears. This ensures smooth continuous tooth engagement, reducing torque ripple during deceleration spikes while lowering acoustic emissions to as low as 56 dBA.
Engineering Checklist for High-Dynamic Motion Profiles
| Metric | Gearhead Spec to Look For |
|---|---|
| Output Standard | ISO 9409-1 Compact Robot Flange |
| Target Torsional Rigidity | 500 to 1,000 Nm/arcmin for high inertia reversing loads |
| Precision Backlash (P0) | Down to <1 arcmin (Single Stage) / <3 arcmin (Double Stage) |
| Emergency Stop Torque | Verify peak ratings up to 3.0x Nominal Output Torque to prevent mechanical deformation |
| Max Input Speed | Up to 10,000 RPM (Frame Sizes 42 & 60) |
| Enclosure Rating | IP65 Sealed, Factory-Filled Synthetic Lubricant |
Automation Application Results: Shorter Cycle Times & Higher Gain Tuning
By removing mechanical compliance within the gearhead, system integrators can tune servo loops with higher proportional gains without triggering control loop resonance or axis hunting.
-
Crisp Deceleration: The robot arm or indexer stops cleanly at target coordinates without position overshoot.
-
Minimized Pauses: Settling delays in the PLC program can be reduced or eliminated, yielding higher parts-per-minute (PPM) rates.
-
Long-Term Precision: Hardened and ground gearing coupled with needle bearing support prevents backlash degradation across millions of high-frequency reversing cycles.
Whether you’re upgrading an existing motion profile or designing a high-dynamic servo system, the PHF Series provides the structural stiffness required to maximize machine throughput and accuracy.