Overcoming Shaft Deflection & Overhung Loads in High-Dynamic Motion Control
Here is why pairing a right-angle servo worm with an integrated rotary flange is becoming the preferred choice for modern machine design.
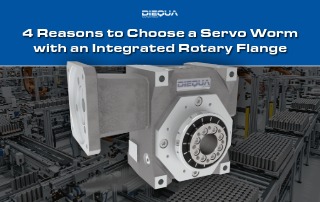
Here is why pairing a right-angle servo worm with an integrated rotary flange is becoming the preferred choice for modern machine design.
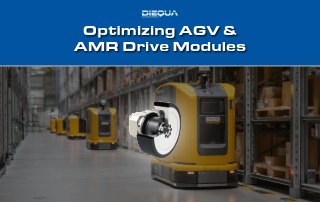
In mobile robotics design, drive module selection is always an exercise in managing trade-offs. As Automated Guided Vehicles (AGVs) and Autonomous Mobile Robots (AMRs) are tasked with carrying heavier payloads in smaller chassis footprints, traditional gearbox-and-wheel layouts quickly run into physical limits. Designing an efficient drive system requires balancing structural load support, energy efficiency for battery preservation, and tight spatial constraints. Here is a look at how specialized planetary gearheads address these specific mechanical bottlenecks.
© 2018 - 2026 DieQua Corporation | All Rights Reserved